∑math20

Dynamical systems and ergodic theory · Result 154

Pointwise multiple ergodic averages for mixing transformations

4 papers

Proves almost-everywhere convergence of consecutive multiple ergodic averages of every finite length for invertible mixing probability-preserving transformations. For each fixed tuple of bounded functions, the limit is the product of their integrals, along all positive averaging lengths. No mixing rate or standardness assumption on the probability space is required.

Watch

▶Introduction: the problem and why it mattersin preparation
▶The presented solutionin preparation

Papers 4

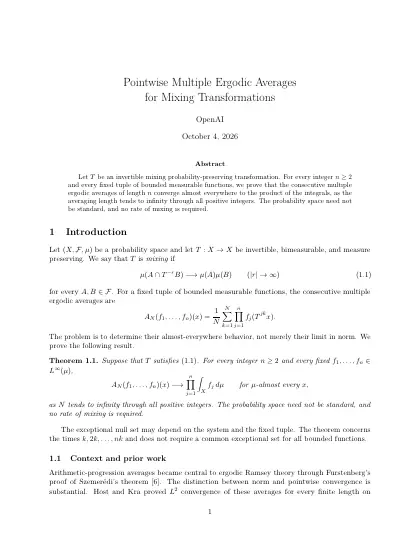
First page of Pointwise Multiple Ergodic Averages for Mixing Transformations

Pointwise Multiple Ergodic Averages for Mixing Transformations

OpenAI · October 4, 2026

Let T be an invertible mixing probability-preserving transformation. For every integer n ≥ 2 and every fixed tuple of bounded measurable functions, we prove that the consecutive multiple ergodic averages of length n converge almost everywhere to the product of the integrals, as the averaging length tends to infinity through all positive integers. The probability space need not be standard, and no rate of mixing is required.

Read PDF Download Source

Cite
@misc{OAI:Pointwise-Multiple-Ergodic-Averages-for-Mixing-Transformations-October-4-2026,
  author = {{OpenAI}},
  title = {{Pointwise Multiple Ergodic Averages for Mixing Transformations}},
  howpublished = {OpenAI Math Release preprint
                  \href{https://github.com/openai/math/blob/main/preprints/Pointwise-Multiple-Ergodic-Averages-for-Mixing-Transformations-October-4-2026/multiple-ergodic-averages.pdf}{OAI:Pointwise-Multiple-Ergodic-Averages-for-Mixing-Transformations-October-4-2026}},
  year = {2026}
}
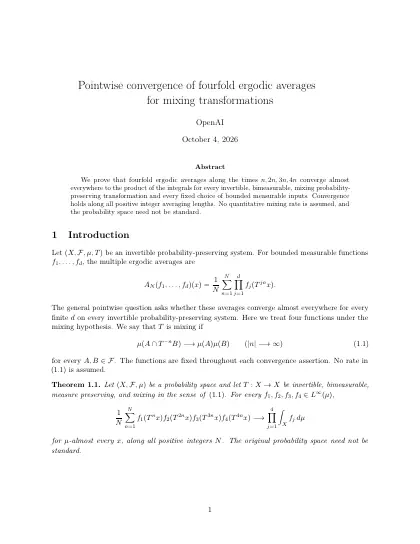
First page of Pointwise convergence of fourfold ergodic averages for mixing transformations

Pointwise convergence of fourfold ergodic averages for mixing transformations

OpenAI · October 4, 2026

We prove that fourfold ergodic averages along the times \(n,2n,3n,4n\) converge almost everywhere to the product of the integrals for every invertible, bimeasurable, mixing probability-preserving transformation and every fixed choice of bounded measurable inputs. Convergence holds along all positive integer averaging lengths. No quantitative mixing rate is assumed, and the probability space need not be standard.

Read PDF Download Source

Cite
@misc{OAI:Pointwise-convergence-of-fourfold-ergodic-averages-for-mixing-transformations-October-4-2026,
  author = {{OpenAI}},
  title = {{Pointwise convergence of fourfold ergodic averages for mixing transformations}},
  howpublished = {OpenAI Math Release preprint
                  \href{https://github.com/openai/math/blob/main/preprints/Pointwise-convergence-of-fourfold-ergodic-averages-for-mixing-transformations-October-4-2026/fourfold-ergodic-averages.pdf}{OAI:Pointwise-convergence-of-fourfold-ergodic-averages-for-mixing-transformations-October-4-2026}},
  year = {2026}
}
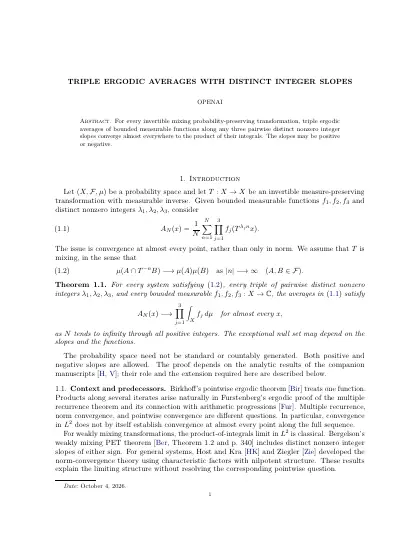
First page of Triple ergodic averages with distinct integer slopes

Triple ergodic averages with distinct integer slopes

OpenAI · October 4, 2026

For every invertible mixing probability-preserving transformation, triple ergodic averages of bounded measurable functions along any three pairwise distinct nonzero integer slopes converge almost everywhere to the product of their integrals. The slopes may be positive or negative.

Read PDF Download Source

Cite
@misc{OAI:Triple-ergodic-averages-with-distinct-integer-slopes-October-4-2026,
  author = {{OpenAI}},
  title = {{Triple ergodic averages with distinct integer slopes}},
  howpublished = {OpenAI Math Release preprint
                  \href{https://github.com/openai/math/blob/main/preprints/Triple-ergodic-averages-with-distinct-integer-slopes-October-4-2026/triple-ergodic-distinct-slopes.pdf}{OAI:Triple-ergodic-averages-with-distinct-integer-slopes-October-4-2026}},
  year = {2026}
}
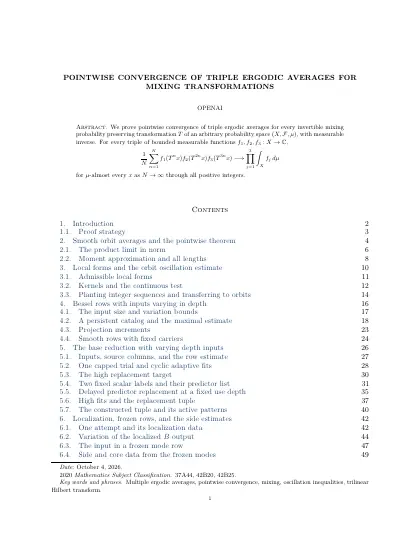
First page of Pointwise convergence of triple ergodic averages for mixing transformations

Pointwise convergence of triple ergodic averages for mixing transformations

OpenAI · October 4, 2026

We prove pointwise convergence of triple ergodic averages for every invertible mixing probability preserving transformation T of an arbitrary probability space \((X,\mathcal F,\mu)\), with measurable inverse. For every triple of bounded measurable functions \(f_1,f_2,f_3:X\to\mathbb C\), \(\displaystyle \frac1N\sum_{n=1}^N f_1(T^nx)f_2(T^{2n}x)f_3(T^{3n}x) \longrightarrow \prod_{j=1}^3\int_X f_j\,d\mu\) for μ-almost every x as \(N\to\infty\) through all positive integers.

Read PDF Download Source

Cite
@misc{OAI:Pointwise-convergence-of-triple-ergodic-averages-for-mixing-transformations-October-4-2026,
  author = {{OpenAI}},
  title = {{Pointwise convergence of triple ergodic averages for mixing transformations}},
  howpublished = {OpenAI Math Release preprint
                  \href{https://github.com/openai/math/blob/main/preprints/Pointwise-convergence-of-triple-ergodic-averages-for-mixing-transformations-October-4-2026/pointwise-triple-ergodic-averages-mixing-transformations.pdf}{OAI:Pointwise-convergence-of-triple-ergodic-averages-for-mixing-transformations-October-4-2026}},
  year = {2026}
}

Formal verification

No Lean formalization is listed for this result yet. The repository notes that unformalized results could have issues.